Frontier robotics company
Pilot underway · Recurring engagement
Initial project: six figures
Company confidential
ANTIM LABS / SIMULATION INFRASTRUCTURE
AI-generated 3D assets and environments for robot training and evaluation.
ANTIM LABSRAISING $2M / SAFE
SCROLL TO ENTER ↓
3D assets
and environments
Since July 2026
ONGOING & COMPLETED
Pilot underway · Recurring engagement
Initial project: six figures
Company confidentialRecurring engagement · Construction simulations
Six-figure LOI signed · Pilot in scoping
Completed project · Five-figure value
SCOPING PILOTS
Real-to-sim training and evaluation for dexterous manipulation using egocentric factory data.
IN PIPELINE
Evaluating every condition and software update in the field is impossible. Simulation makes those tests repeatable and scalable.
Use field data to recreate operating conditions.
Vary conditions and compare builds at scale.
Bring new edge cases back into simulation.
Every asset shown was created by our world agent,
compressing weeks of manual work into minutes.
 REAL
 REAL
 REAL
 REAL
Real-to-sim assets, articulation, and material interactions.
04 / REAL-WORLD INTERACTION DATA
Real and simulated grasping, deformation, and squeezing.
Grasp & deformation / Plastic cup
Squeeze & dispense / Bottle
We measure real interactions to estimate physical properties.
From factory floors to open fields, simulate the worlds where robots operate.
INFRASTRUCTURE
Test connector-level interactions.
LOGISTICS
Simulate warehouse operations.
INDUSTRY
Test robots on the factory floor.
AERIAL ROBOTICS
Simulate flights through a neighborhood.
AUTONOMY
Test the same city in different light.
FIELD ROBOTICS
Simulate solar-field installation.
MANIPULATION
Test manipulation in a kitchen.
Recorded Antim environments
06 / EVALUATION PLATFORM · IN DEVELOPMENT
Turn field failures into repeatable simulation tests.
Scenario-generation demos for the evaluation platform in development.
Simulations built around your robot, task, and deployment environment.
Generate simulation-ready assets and scenes from text and images.
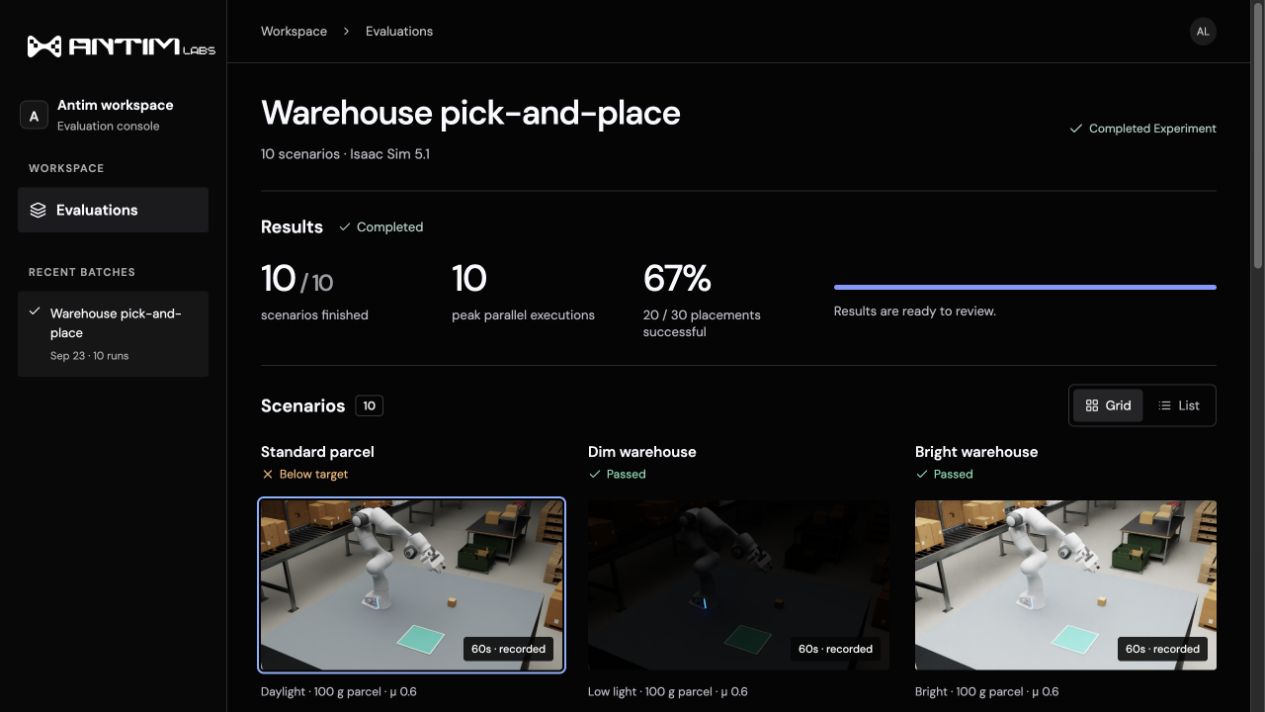
Automated evaluations on Newton, with hosted inference and regression testing.
AI, 3D, and physics experience. Co-founders met at Columbia.
Co-founder / CEO
Applied Statistics, Columbia
Built machine-learning and animation systems for real-time 3D digital humans.
Co-founder / President
Electrical Engineering, Columbia
Physics simulation research and signal-processing experience.
Co-founder / CTO
Computer Science, Columbia
Built applied AI systems and published machine-learning research.$25M cap on a SAFE
$1.3MActive Capital · Untapped VC